

A robot computer may handle perception, planning, networking and control, but those jobs have different timing needs. An ArmSoM SBC or module can host Linux applications while other hardware handles tightly bounded control. Define that split before selecting processors.

ArmSoM Sige5
Assign failure behavior as well as tasks
For each function, state what happens if its process stops, input becomes stale or the network disappears. Keep actuator control and emergency behavior tied to a suitable, validated implementation. Test communication between the Linux host and controllers under delay and restart conditions. More compute does not by itself make a control system dependable.
Define failure behavior before performance targets
Specify what happens when a camera stops, the network drops, the process crashes or power falls. Use timestamps and command expiry where appropriate. Test these cases with actuators disabled or on a safe test rig first. A fast object detector does not prove that the complete robot reacts safely.
Measure the complete perception loop
Record capture-to-decision time, missed frames and variation under simultaneous logging and communication. Confirm that model conversion preserves the needed accuracy. Size power and cooling for sustained operation in the final enclosure. Document which functions the NPU performs and which remain on CPU, GPU or another controller.
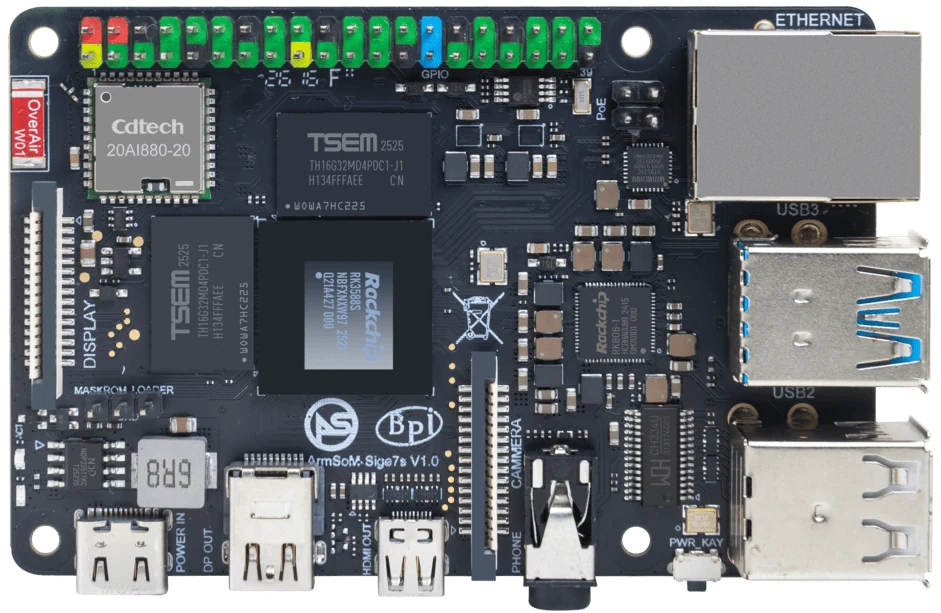
ArmSoM Sige7s
Match the choice to your requirements
Requirement or situation | What to evaluate | Decision detail |
Application computer | Perception, UI and networking | Validate load and recovery. |
Actuator controller | Timing and bounded commands | Define loss-of-command behavior. |
System design | Power, emergency response and testing | Evaluate independently of AI accuracy. |
Example design
Put robot interfaces into a latency and safety budget
A mobile robot might use a Linux board for perception and planning while a separate controller handles motor timing and stop behavior. Define camera bandwidth, sensor updates, command deadlines and recovery after communication loss. Choose the computer from that complete workload. An integrated NPU is relevant only when the intended model and input pipeline work reliably within the system’s timing budget.
Hardware and documentation
Sige5 · RK3576
RK3576, four Cortex-A72 and four Cortex-A53 cores, 6 TOPS NPU, dual Gigabit Ethernet and M.2 PCIe 2.1 x1.
Hardware documentation · Product details
Sige7s · RK3588S
RK3588S, 6 TOPS NPU, Gigabit Ethernet and removable eMMC. Dimensions: 85 × 56 × 17 mm. Disconnect power before replacing eMMC.
Hardware documentation · Product details
Frequently asked questions
Is an NPU required for every robot?
No. The perception workload and software determine whether acceleration is useful.
Product information and support
Sources
Written by ArmSoM using the documentation below. Example designs are proposals, not measured customer installations.